


A "come here" behavior for the Unitree GO2 quadruped. A person says "come here", the robot says "I am coming.", turns toward the voice using the microphone array's direction estimate, finds the caller with its front camera, walks up to them, stops about 0.8 m away and sits. Say "good boy" while it is seated and it stands back up and listens for the next "come here".
Everything runs on the Jetson Orin NX payload on the robot, with no network dependency at runtime.
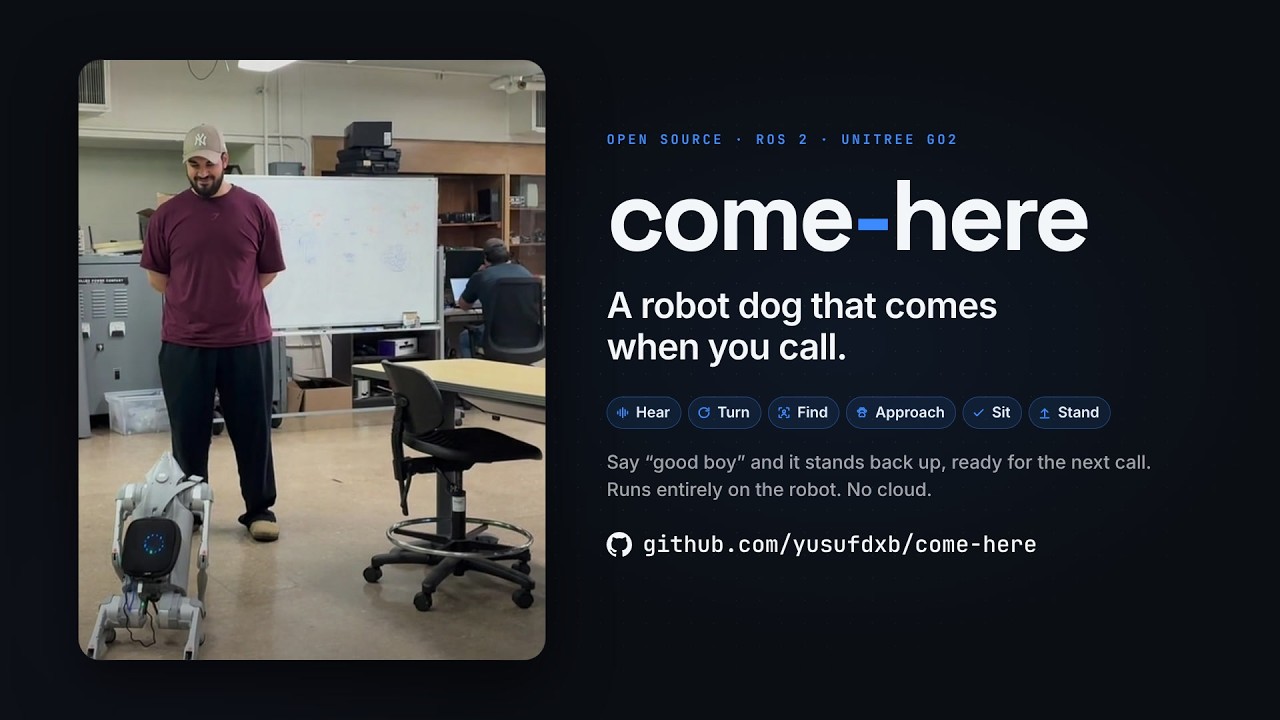
Three live runs on the GO2, each played start to finish (click to watch). Waiting and some walking stretches are sped up 2x and labeled; every spoken line plays at real speed.
source scripts/demo_env.sh
./scripts/demo_preflight.sh                                              # never moves the robot
ros2 launch come_here_bringup professor_demo.launch.py                   # dry run: robot never moves
ros2 launch come_here_bringup professor_demo.launch.py dry_run:=false    # live
ros2 run come_here_behavior estop_console                                # second terminal
The operator runbook, safety rules, lab validation ladder and recovery steps are in docs/professor_demo.md. All demo parameters live in come_here_bringup/config/professor_demo.yaml, one comment per value.
stateDiagram-v2
    [*] --> IDLE
    IDLE --> LISTENING: "come here" heard
    LISTENING --> TURN_TO_SOUND: confident voice bearing beyond 0.2 rad
    LISTENING --> ACQUIRE_PERSON: voice ahead
    TURN_TO_SOUND --> ACQUIRE_PERSON: closed-loop turn on odometry yaw
    ACQUIRE_PERSON --> ALIGN: 2 fresh detections, off-center
    ACQUIRE_PERSON --> WALK: 2 fresh detections, centered
    ALIGN --> WALK: bearing inside 0.15 rad
    WALK --> ALIGN: bearing beyond 0.30 rad after 1.5 s
    ALIGN --> ACQUIRE_PERSON: caller lost (stop)
    WALK --> ACQUIRE_PERSON: caller lost (stop)
    ACQUIRE_PERSON --> LISTENING: nobody seen, "Where are you?" (once)
    ACQUIRE_PERSON --> IDLE: 10 s without the caller
    WALK --> ARRIVED: bbox height >= 82% of frame, or walk budget reached on the caller
    ARRIVED --> SIT: align, settle, sit, speak
    SIT --> IDLE: "good boy", operator reset (estop_console) or remote, then stand and settle 3 s
| Stage | What happens |
|---|---|
| Wake | ReSpeaker Mic Array v2.0 beamformed channel, an adaptive energy gate with pre-roll, faster-whisper base.en int8 on the CPU (capped at 2 threads), fuzzy match on "come here". |
| Direction | The ReSpeaker built-in DOA (DOAANGLE, offset -90 deg on this mount), one bearing per matched utterance. The bridge turns in place until /utlidar/robot_odom yaw has moved by that bearing. Without a confident bearing the robot does not walk. |
| Acquire | YOLO11n person detection, once per new camera frame, only inside a +/-35 deg gate around the voice bearing. Two consecutive fresh detections are required before any motion. If nobody is in view after the voice turn (4 fresh empty frames or 2 s), the robot says "Where are you?" once and turns toward the next "come here" (8 s wait); if that fails too, it scans a full circle in 45 deg steps. |
| Align / walk | The stock mcf gait cannot combine forward motion and yaw cleanly, so ALIGN turns in place (yaw only) and WALK goes straight (0.6 m/s, no yaw), with hysteresis and minimum phase times. The bridge republishes Move at 20 Hz to keep the gait latched. |
| Stop | The person's bounding box filling 82% of the frame height (LiDAR and pinhole distance read long at close range). Backstops: caller lost for 0.3 s, no valid detection for 1.5 s, a dead camera, a 20 s approach limit and a commanded walking-distance budget. |
| Arrive | Final yaw-only align, 1 s standing still, Sit, "Made it." / "Here I am.", stay seated until "good boy" or an operator reset. |
| Good boy | "good boy" is matched as its own whole-token phrase and is never a wake. While the robot is seated it sends RiseSit (Sport API 1010); after stand_settle_s (3 s) the behavior returns to IDLE and accepts the next "come here". Set by praise_enabled and praise_stands_up in the demo config. |
skip_turn_to_sound:=true restores the camera-only behavior. scripts/install_come_here_service.sh --enable installs a systemd service that starts the stack at boot (dry run unless .come_here_live exists in the checkout).
- Motion gate (
go2_bridge_node+ puremotion_gate.py): rejects malformed, non-finite and absurd velocity commands (they stop the robot), clamps valid ones, rejects combined forward + yaw, and stops the robot 0.5 s after commands stop arriving. - E-stop:
/come_here/estoptrue latches in both the bridge and the state machine. Release does not resume motion; a new "come here" is required. - Motion mode: the bridge sends a read-only CheckMode and refuses all motion unless the robot reports
mcf. Nothing in this repository sends SelectMode, and the bridge refuses to start with api id 1001 (Damp) configured on the Sport topic. - Shutdown: Ctrl+C or SIGTERM publishes StopMove before the process exits (verified by a process-level test with an independent subscriber).
- Dry run:
dry_run:=true(the demo default) sends Sport requests to/come_here/dry_run/sport_requestinstead of the robot.
| Package | Role |
|---|---|
come_here_msgs |
Message definitions |
come_here_audio |
Whisper wake phrase detector and far-field front end, ReSpeaker DSP tuning, microphone selection, DOA provider |
come_here_perception |
YOLO person detector, LiDAR distance resolver, face detector (experimental) |
come_here_behavior |
State machine (come_here_fsm.py), behavior node, GO2 bridge, motion gate, trial log, operator tools |
come_here_bringup |
professor_demo.launch.py (supported) and come_here.launch.py (experimental) |
Main topics: /come_here/wake_phrase, /come_here/person_detection, /come_here/cmd_velocity ([vx, yaw_rate]), /come_here/estop, /come_here/state, /come_here/trial_summary, /come_here/bridge_status, /come_here/audio_health.
source /opt/ros/humble/setup.bash
colcon build --symlink-install
source install/setup.bash
for p in come_here_behavior come_here_audio come_here_perception come_here_bringup; do
  (cd $p && python3 -m pytest test -q)
done
Run pytest from inside each package: every package ships a test/__init__.py, and running them in one session collides. Tests that import the GO2 bridge need the Unitree unitree_api message package and are skipped without it.
Each trial appends a JSON line to ~/come_here_trials/trials.jsonl (git commit, wake source and latency, acquisition latency, ALIGN/WALK counts, lost events, stop reason, final bounding box, e-stop, success). ros2 run come_here_behavior trial_report prints a PASS/FAIL table and records operator verdicts.
Live end-to-end trials on the physical GO2, running onboard the Jetson Orin NX. The full sequence is wake phrase, caller direction, turn, visual person acquisition, approach, stop, sit. Each row is one trial, successes and failures alike. Only the trials listed here are claimed as live end-to-end results; the trial logs from 2026-09-14 and 2026-09-15 also hold dry runs, staged tests and attempts that did not complete.
| Date | Trial ID | Caller | What happened | Result |
|---|---|---|---|---|
| 2026-09-14 | 19700105T111547-001 (robot clock unset) |
Robot's left, about 90 deg | Bearing +34 deg, turn, one search turn, align, walk, bounding-box stop, sit | Success |
| 2026-09-15 | 20260915T224403-001 |
Robot's right | Bearing read +141 deg, nobody acquired | Failed (acquire_timeout) |
| 2026-09-15 | 20260915T225451-001 |
Robot's right | Bearing -100 deg, turn, walk, bounding-box stop, sit | Success |
| 2026-09-15 | 20260915T230644-001 |
Blind trial (caller position undisclosed) | Bearing -59 deg, turn, align, walk, bounding-box stop, sit; DONE: sitting about 12.8 s after wake-phrase detection |
Success |
| 2026-09-18 | 20260918T204123-001 |
Robot's left | Bearing read +2 deg (straight ahead), so no turn; nobody in the camera view and, on that build, no search turn for a straight-ahead bearing; the robot did not move | Failed (acquire_timeout) |
| 2026-09-18 | 20260918T204123-002 |
Robot's right | Bearing -74 deg, turned -71 deg, one 23 deg align turn, walk, bounding-box stop (0.83 of frame height), sit; DONE: sitting about 12.5 s after wake-phrase detection |
Success |
| 2026-09-23 | Not captured | Not recorded | First call read +0.09 rad (ahead), no turn, nobody in view; the robot asked "Where are you?", heard a second "come here" at +0.19 rad, acquired the caller, walked and stopped on the bounding box, entering the sit state about 13.0 s after the first wake-phrase detection | Approach completed; the sit-complete log line and trial ID were not captured |
These runs show that the complete behavior executes on hardware. They are not a robustness or performance study, and the timings describe single trials, not typical timing.
Boot service. On 2026-09-18 the systemd service started the live stack by itself after a cold boot of the Jetson: its first attempt exited NOT READY because the robot network interface was not up yet, systemd retried, and the retry launched live with the robot standing. Both 2026-09-18 trials and the 2026-09-23 trial ran on a stack started this way.
Relisten. The 2026-09-23 trial is the one live run of the relisten step, which is on main since f7192c9 (the behavior node reported git=f7192c9a95). It was added after the 2026-09-18 straight-ahead failure: when nobody is in view after the voice turn, the robot asks "Where are you?" once and turns toward the next "come here" before any search sweep.
Source state. For the 2026-09-14, 2026-09-15 and 2026-09-18 trials the robot checkout was recorded as 047825b with uncommitted changes, which were committed afterwards on this line; the exact executed source state is not fully reconstructable from Git history.
Operator note. In the 2026-09-15, 2026-09-18 and 2026-09-23 sessions a bump of the remote's stick while the robot was handled latched the e-stop, as designed; each time it was released from estop_console before the next trial.
| Subsystem | Hardware evidence |
|---|---|
| Wake phrase (far-field front end, whole-token "come here" matcher) | Live wakes in the trials above (2026-09-14 to 2026-09-23); 49 of 57 recorded "come here" and 0 false wakes on replay |
| Turn toward the voice (built-in DOA + closed-loop odometry turn) | Live successes with the caller at the robot's left (2026-09-14), right (2026-09-15, 2026-09-18) and in the blind trial; failures: a right-side call read +141 deg (2026-09-15) and a left-side call read +2 deg (2026-09-18) |
| Relisten ("Where are you?", second call) | One live trial on 2026-09-23: second call heard and approached; sit completion not captured |
| YOLO acquisition, ALIGN / WALK, bounding-box stop, sit | Demonstrated in the live trials above |
| Motion gate, mcf check, e-stop, shutdown stop, dry run | Unit and process tests; the remote-stick e-stop latched on the robot on 2026-09-15, 2026-09-18 and 2026-09-23 |
| Boot service | Live boot path exercised on 2026-09-18 (cold boot, first attempt NOT READY, systemd retry launched live) and used again on 2026-09-23 |
| "Good boy" stand-up and return to IDLE | Seen in two runs filmed by the caller (runs 2 and 3 of the demo video): the robot stands after "good boy"; no trial log or trial IDs were captured for those runs |
| Face detection after sitting | Not working: no face detected from the seated camera view |
- One caller. Nobody closer to the robot than the caller.
- The voice bearing is occasionally wrong (a held DOA register, or a side caller read as straight ahead); the relisten step and the full-circle scan recover some of these.
- Wake range with the robot's own noise is not yet measured with the new front end.
- LiDAR distance reads long while walking at close range; the bounding-box fraction carries the stop.
- The mcf forward gait drifts left about 0.1 to 0.2 m over 3 s of walking.
- YOLO runs on the Jetson CPU (about 1 to 2 Hz measured in April 2026).
- The camera publisher script that feeds
/camera/image_rawlives on the robot's payload, not in this repository.
training/ holds an optional LoRA fine-tuning pipeline for the Whisper detector (record_samples.py, finetune_whisper.py, evaluate.py). It is not needed at runtime.
MIT, see LICENSE.
Yusuf Guenena · yusuf.a.guenena@gmail.com