


UFACTORY robot simulation and reinforcement learning examples built on Genesis.
中文 | Simulation | Reinforcement learning

Supports xArm5, xArm6, xArm7, UF850 and Lite6. See the robot and gripper combinations.
- Robot and gripper visualization: GLB models, movable fingers and gripper opening/closing demos.
- Gripper G2 calibrated dynamics: percentage control, standalone cube grasp and dynamics acceptance.
- Kinematics and contact simulation: FK/IK verification and physics checks.
- Trajectory-controlled pick & place: pick up, transfer and place objects.
- Box packing simulation: YAML-configured trajectories and contact simulation.
Installation and complete commands are in the examples guide.
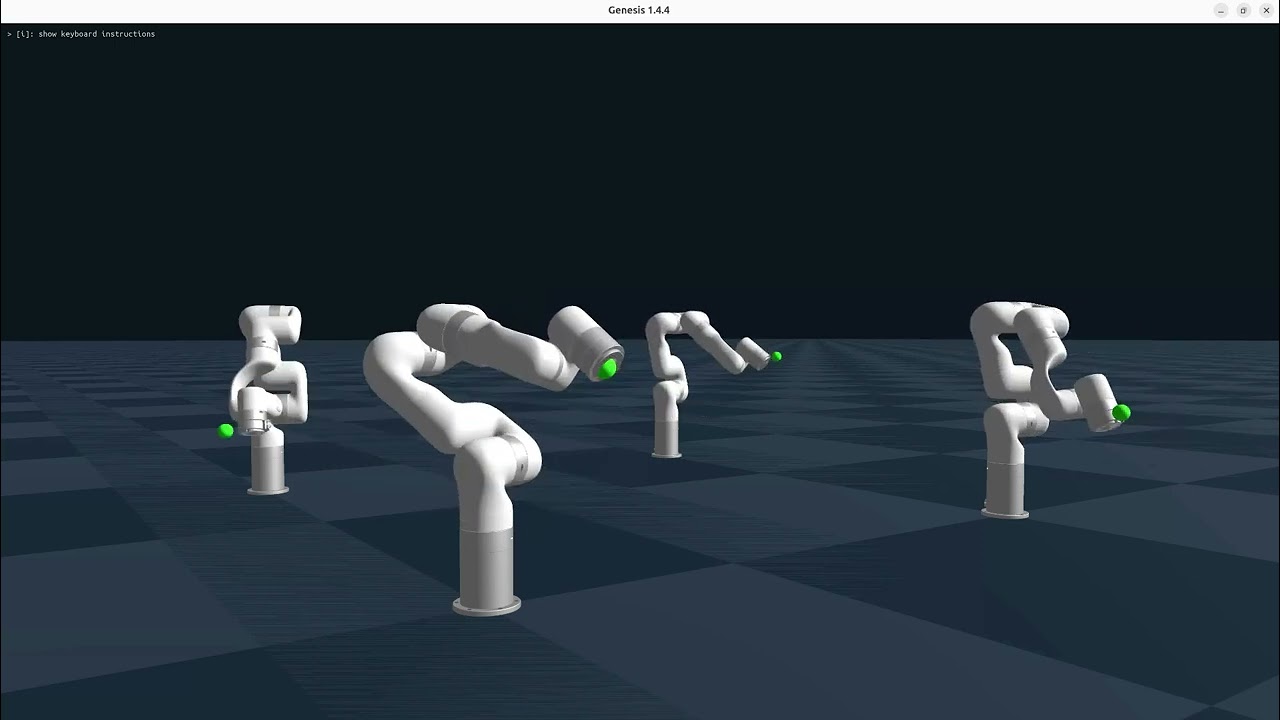
Simulation-only training and inference on Linux/NVIDIA GPUs. See the RL index for the task progression and guides.
- Reach: target reaching — Move the end effector of an xArm6 without a gripper to a target with a success distance strictly below 5 mm. Supports single-arm and four-arm real-time GLB inference. No Reach weights are bundled.
- Pick & Place: tabletop — xArm6 + Gripper G2 grasps and transfers a cube to a tabletop target. Uses a fixed
+Ylayout with scripted action guidance; reference weights are included.
- Hardware and real-robot operation
- Dynamics checks
- Contributing and project checks
- Current entry points · Roadmap · Changelog
Real motion requires per-unit calibration, predictive preflight and explicit confirmation. See the safety requirements.
Code is MIT licensed; robot URDF and mesh assets include upstream material with separate attribution in NOTICE.
For research use, cite “genesis-ufactory: UFACTORY Robot Models for Genesis Simulation,” UFACTORY, 2026, https://github.com/xArm-Developer/ufactory_genesis.