


The driver implements Cyphal ESC service support for up to 8 ESC like Myxa, Mini node and kotleta20.
It publishes:
- uavcan.node.Heartbeat with 1 Hz rate,
- reg.udral.service.common.Readiness with 10 Hz rate,
- reg.udral.service.actuator.common.sp with maximum possible rate.
It subscribes on:
The driver introduces the following ArduPilot parameters:
| CYP_ENABLE | 1 | 1 means Cyphal is enabled, 0 means disabled Default: Enabled |
| CYP_NODE_ID | 1-127 | Node identifier in Cyphal-network. Usually, 127 is reserved for debugging tools and 1 is used for an autopilot. Default: 1 |
| CYP_TESTS | 0 | If set to 1, the driver analysis his own performance and enables extra verbosity to GCS Default: Disabled |
| CYP_RD | 1-8191 | Readiness port id. Enabled if less then 8191, otherwise disabled. Default: 65535 (disabled). |
| CYP_SP | 1-8191 | Setpoint port id for ESCs. Enabled if less then 8191, otherwise disabled. Default: 65535 (disabled). |
| CYP_FB | 1-8191 | ESC Feedback array of port id. Enabled if less then 8191, otherwise disabled. When enabled, it occupies 8 consecutive port identifiers. For example, if it is 3000, it will occupy [3000, 3007] identifiers. Default: 65535 (disabled). |
Limitation
The driver does not provide support for the following features:
Any modern flight controller and ArduPilot firmware with scripting support should be suitable.
Tested on Pixhawk6C, CuavV6X and CubeOrange with Copter and ArduPlane firmware v4.4.4 and v4.4.7.
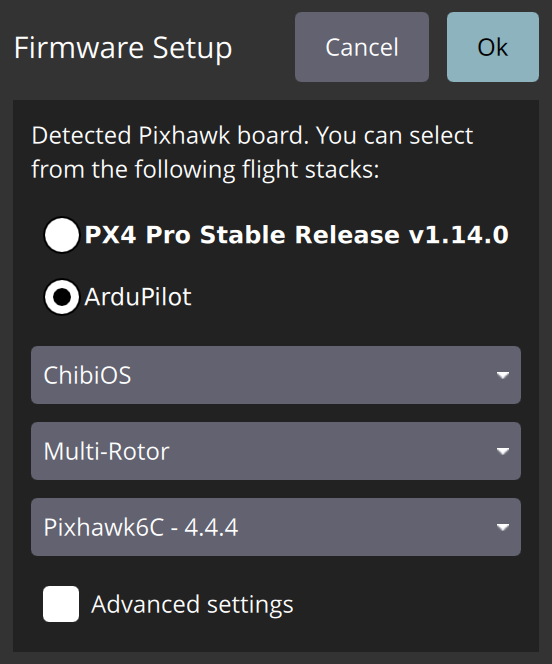
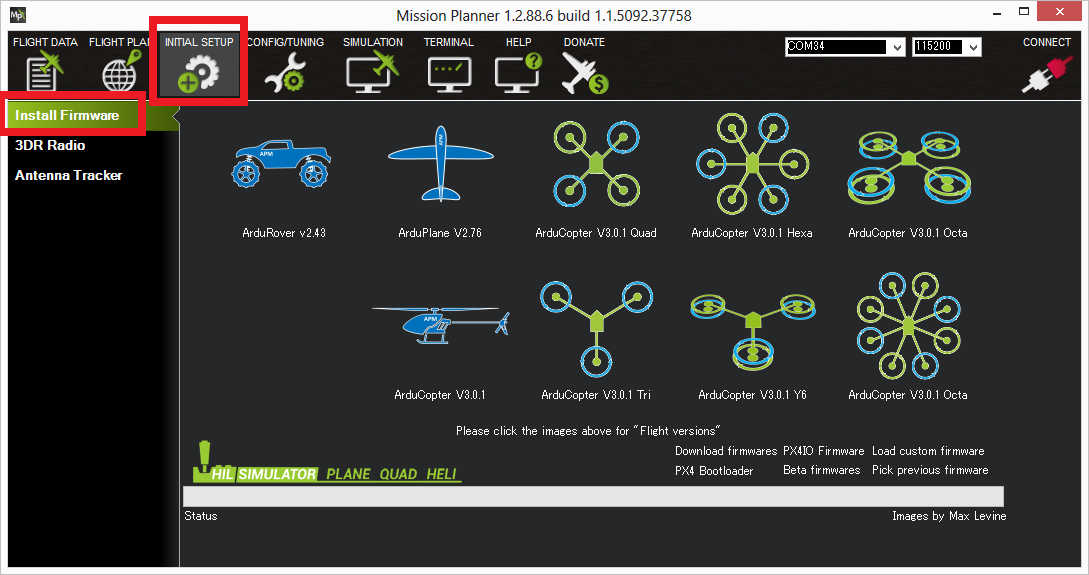
Option 1. Upload the latest stable fimware with QGroundControl or MissionPlanner.
| QGroundControl | MissionPlanner |
|---|---|
 |
 |
Option 2. Build and upload firmware manually from source code.
./waf list_boards
./waf configure --board CubeOrange # Pixhawk6C, Pixhawk6X
./waf copter
./waf --targets bin/arducopter --uploadThis driver should be loaded by placing the lua script in the
APM/scripts directory on the microSD card.
Opion 1. Upload Cyphal.lua script with a helper python script
pip install -r requirements.txt
./upload.py -c /dev/ttyACM0 # use a path to the flight controler
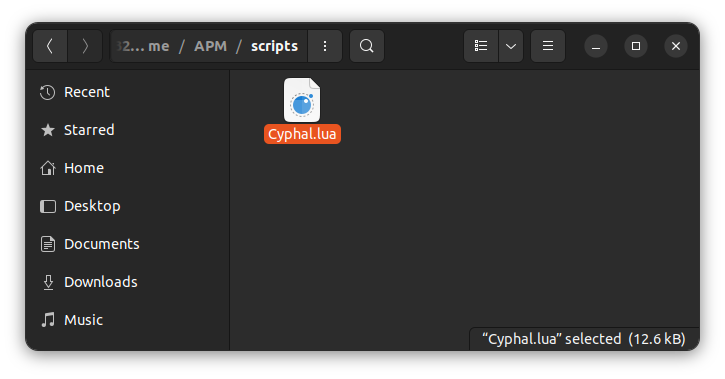
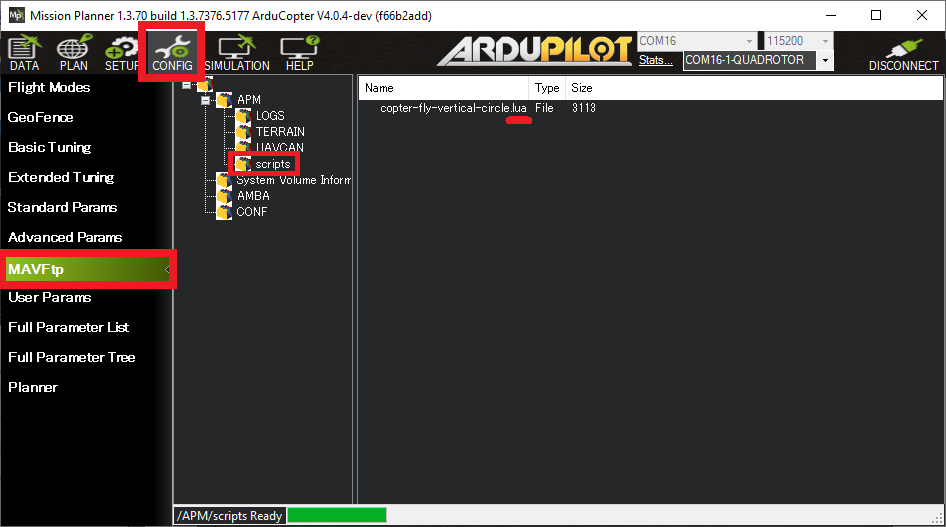
Option 2. Upload the script with card reader or using MissionPlanner
| Copy directly | Using MAVFtp |
|---|---|
 |
 |
The following parameters should be set to start the script and configure the CAN driver:
| SCR_ENABLE | 1 - means scripting is enabled, 0 means disabled |
| CAN_D1_PROTOCOL | 10 - means scripting |
| CAN_P1_DRIVER | First driver |
| CAN_P1_BITRATE | 1000000 - Default bitrate for most of the applications |
Then reboot the flight controller and Cyphal parameters should appear. If the parameters don't appear, try Refresh button in QGC or restart the GCS. You need to configure these:
| CYP_SP | Enable publishing sp.Vector. Choose any value withing [1, 7167]. For example, 2000. |
| CYP_RD | Enable publishing Readiness. Choose any value withing [1, 7167]. For example, 2001. |
| CYP_FB | Enable subscribing on a group of CompactFeedbacks. Choose any value withing [1, 7167]. For example, 3000. |
Then reboot the flight controller.
Configure the yakut-related environment variables, connect autopilot and CAN-sniffer together.

If you run y mon, you should get:
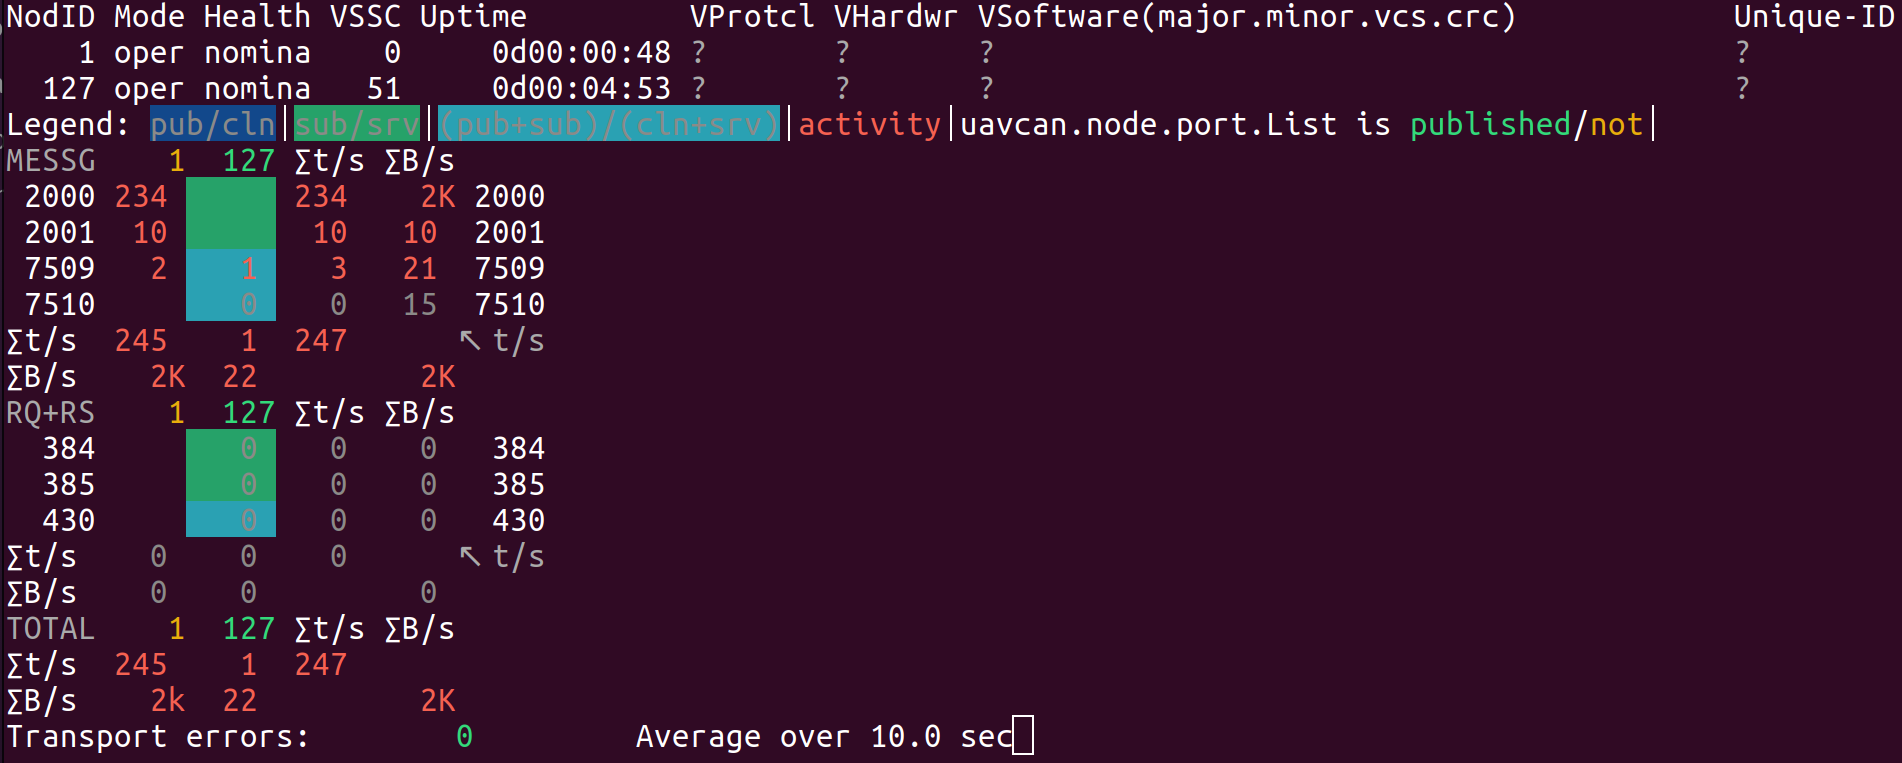
Here, we have 2 nodes: autopilot with node_id=1 (it is configured in CYP_NODE_ID) and yakut with node_id=127. The autopilot publishes setpoint with port_id=2000 (CYP_SP) with ~234 Hz and readiness with port_id=2001 (CYP_RD) with ~10 Hz.
Since the node doesn't support anything except
uavcan.node.Heartbeat, it doesn't have a name and registers are not avaliable via Cyphal/CAN interface.
Additionally, you can subscribes to the setpoint and readiness topics:
y sub 2001:reg.udral.service.common.Readiness
y sub 2000:reg.udral.service.actuator.common.sp.Vector8
./emulate_zubax_myxa_feedback.py1. Insufficent memory loading
Try to disable some feature as it is recommended on the ardupilot forum.
For example, LOG_FILE_BUFSIZE = 8 can help.
2. Why Cyphal paramters are float?
Docs says all scripting defined parameters are of type FLOAT, ie floating point numbers.