Repository navigation
Add Hybrid A* trailer path planning animation - #19
Draft
AtsushiSakai wants to merge 1 commit into
Draft
AtsushiSakai wants to merge 1 commit into
AtsushiSakai wants to merge 1 commit into
Conversation


Owner
Author
|
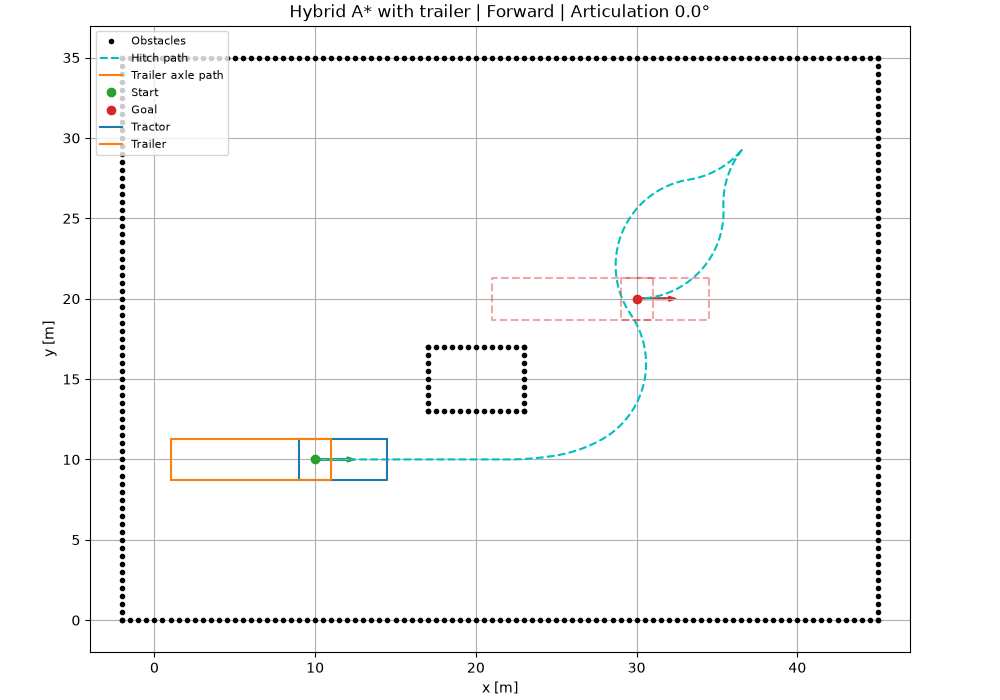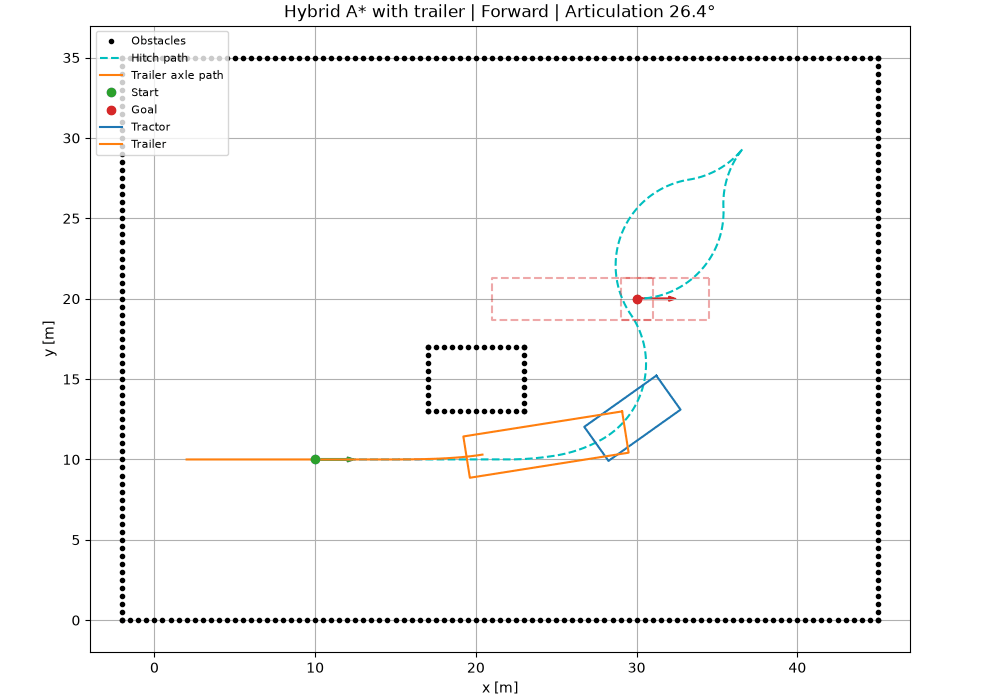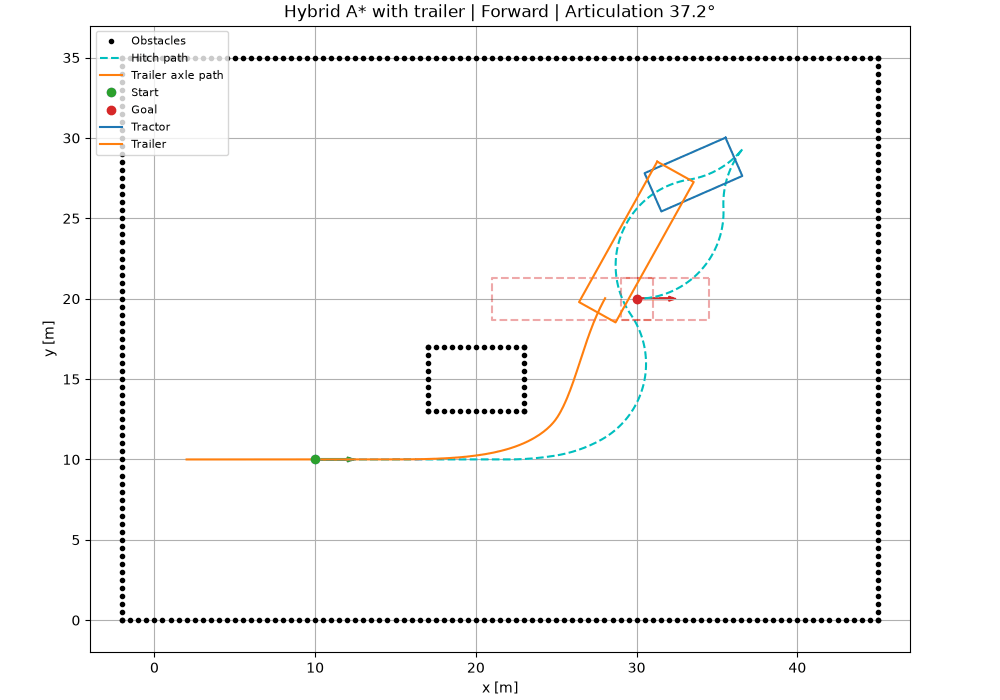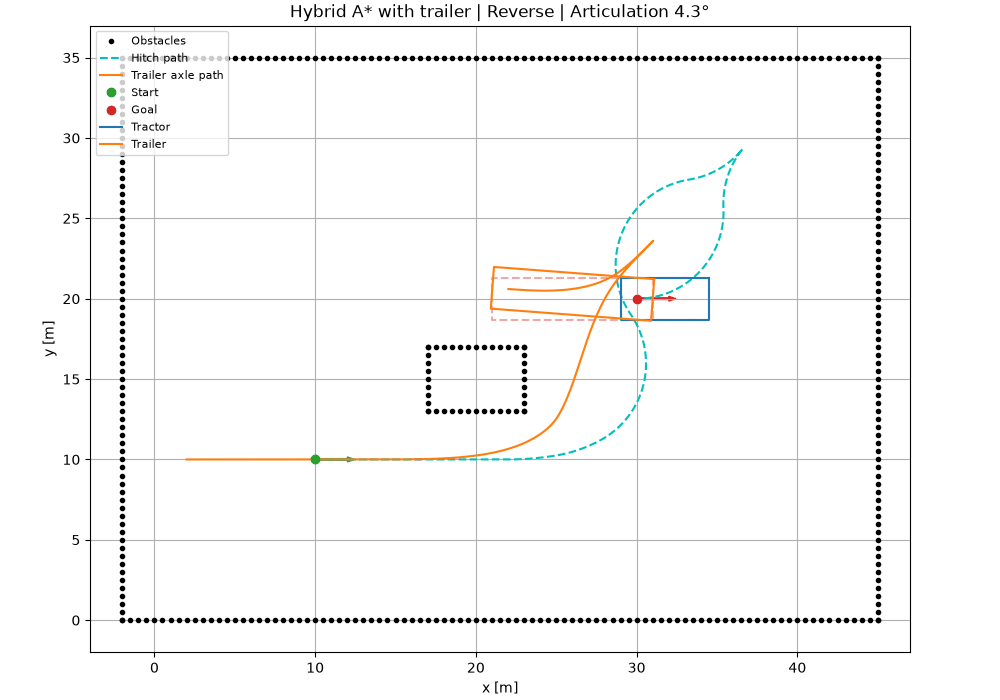
Hybrid A* trailer example for AtsushiSakai/PythonRobotics#1243. The tractor is blue, the trailer orange, the planned hitch path cyan, and the goal red. The title shows direction and articulation.
|
3 tasks done
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters.
Learn more about bidirectional Unicode characters
Sign up for free
to join this conversation on GitHub.
Already have an account?
Sign in to comment
1 participant

Add this suggestion to a batch that can be applied as a single commit.This suggestion is invalid because no changes were made to the code.Suggestions cannot be applied while the pull request is closed.Suggestions cannot be applied while viewing a subset of changes.Only one suggestion per line can be applied in a batch.Add this suggestion to a batch that can be applied as a single commit.Applying suggestions on deleted lines is not supported.You must change the existing code in this line in order to create a valid suggestion.Outdated suggestions cannot be applied.This suggestion has been applied or marked resolved.Suggestions cannot be applied from pending reviews.Suggestions cannot be applied on multi-line comments.Suggestions cannot be applied while the pull request is queued to merge.Suggestion cannot be applied right now. Please check back later.
Add the Matplotlib animation for AtsushiSakai/PythonRobotics#1243. It shows a tractor with one passive trailer navigating around an obstacle and reversing into the goal. Tractor/hitch and trailer-axle trajectories, both body outlines, desired goal outlines, motion direction, and articulation are visible.
Generated from the new Hybrid A* trailer example with PillowWriter: 1000 × 700 pixels, 93 frames, approximately 1.2 MB. Inspected the start, turning, and final frames. The example reaches the tractor goal with a 4.34° trailer heading error (5° tolerance), with a maximum articulation of 70.01° (75° limit).
Implementation PR: AtsushiSakai/PythonRobotics#1456