





Robotics software engineer at MAP IV (TIER IV group), based in Japan.
I build open-source tools for SLAM, localization, and sensor fusion across GNSS, LiDAR, Visual, and IMU, plus performance-oriented robotics systems in C++ and ROS 2.


- lidar_slam_ros2 · 850 stars · ROS 2 LiDAR SLAM for pointcloud-map authoring, benchmarking, and Autoware-compatible map workflows.
- lidar_localization_ros2 · 560 stars · 3D LiDAR localization with NDT/GICP and pointcloud maps in ROS 2.
- li_slam_ros2 · 432 stars · Tightly-coupled LiDAR inertial SLAM for ROS 2.
- kalman_filter_localization_ros2 · 369 stars · GNSS / IMU localization using Kalman filtering.
- rust_robotics · 262 stars · Robotics algorithms and reference implementations in Rust.
- gnssplusplus-library · 220 stars · Modern C++ GNSS / RTK / PPP / CLAS toolkit.
- lidar_localizer · 187 stars · LiDAR localizer for Autoware AI.
- CudaRobotics · 137 stars · CUDA-accelerated robotics algorithms in C++ with 20+ SLAM, planning, and localization demos.
- gnss_gpu · 84 stars · GPU particle-filter GNSS positioning for the urban canyon with ray-traced NLOS rejection and factor-graph optimization.
- visloc-rs · 71 stars · Visual and visual-inertial SLAM, SfM, and localization in pure Rust.
- PoseOptimizationSLAM3D · 68 stars · Python sample code for 3D pose-optimization SLAM.
- localization_zoo · 55 stars · C++ from-paper reimplementations of LiDAR localization and odometry papers, with benchmarks and tests.
- SpatialRust · 22 stars · Rust-native spatial computing for point clouds, computer vision, and GPU compute without a C++/FFI layer.
- CloudAnalyzer · 13 stars · CLI-first QA toolkit for point clouds, trajectories, and 3D perception outputs.
- RoboSim · 10 stars · Robot-native Rust simulation engine with physics, sensors, Python bindings, and optional ROS 2 adapters.
|
lidar_slam_ros2 850 stars ROS 2 LiDAR SLAM for pointcloud-map authoring, benchmarking, and Autoware-compatible map workflows. 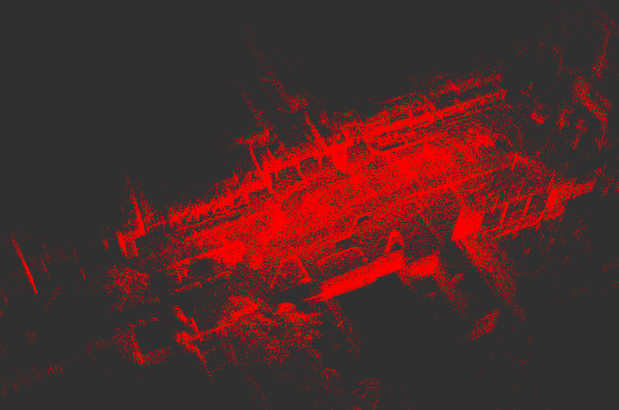
|
li_slam_ros2 432 stars Tightly-coupled LiDAR inertial SLAM for ROS 2. 
|
|
kalman_filter_localization_ros2 369 stars GNSS / IMU localization using Kalman filtering. 
|
lidar_localization_ros2 560 stars 3D LiDAR localization with NDT/GICP and pointcloud maps in ROS 2. 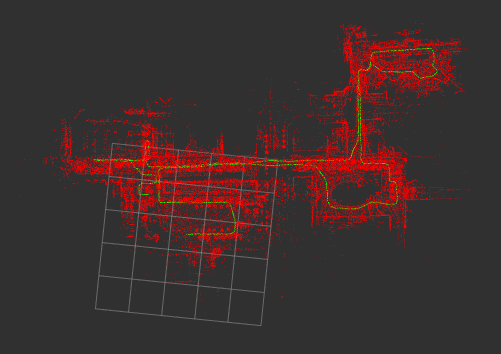
|
|
rust_robotics 262 stars Robotics algorithms and reference implementations in Rust. 
|
gnssplusplus-library 220 stars Modern C++ GNSS / RTK / PPP / CLAS toolkit. 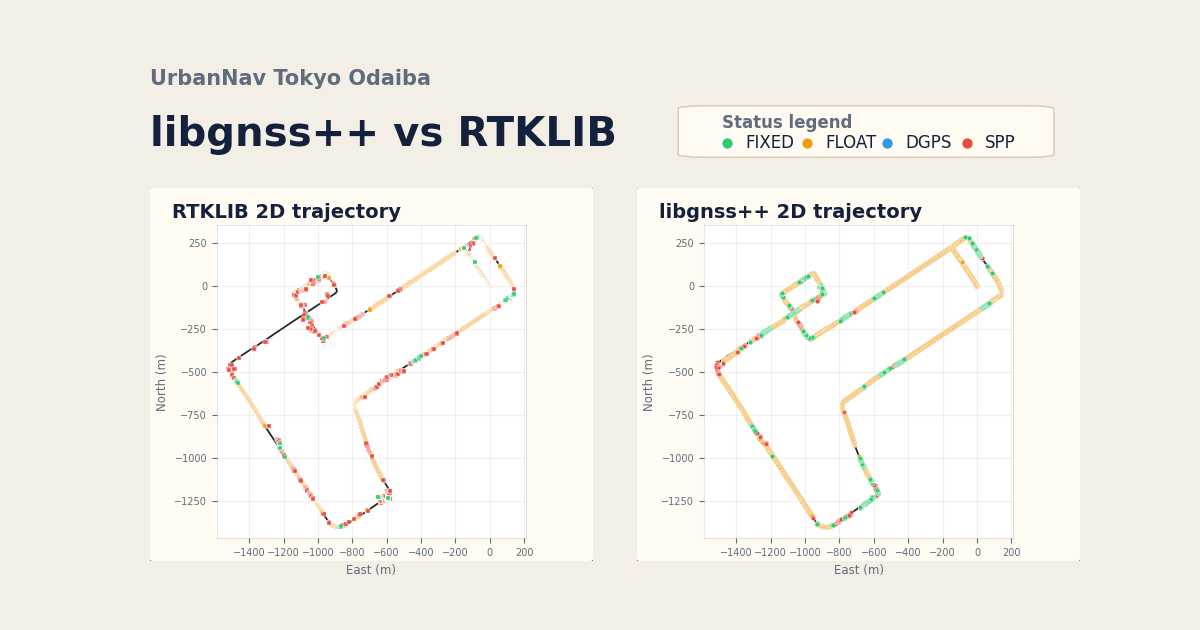
|
|
gnss_gpu 84 stars GPU particle-filter GNSS positioning for the urban canyon with ray-traced NLOS rejection and factor-graph optimization. 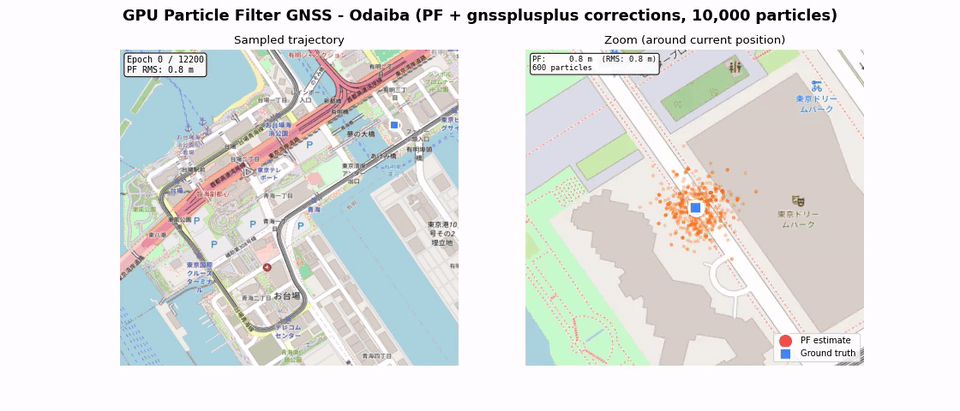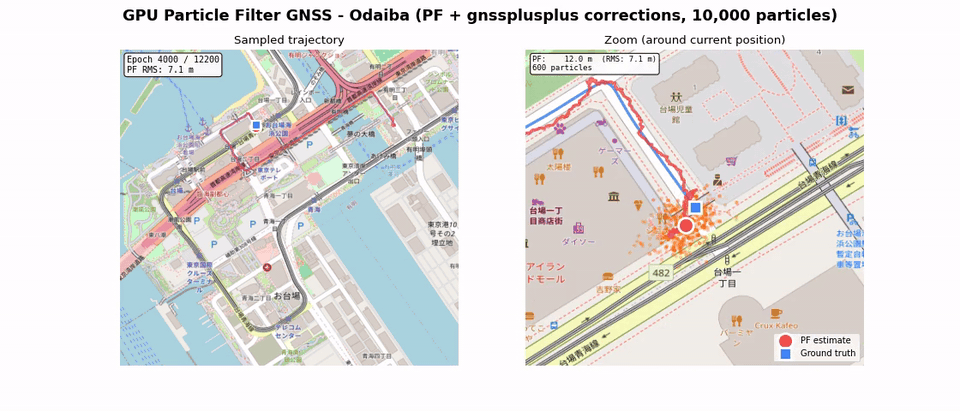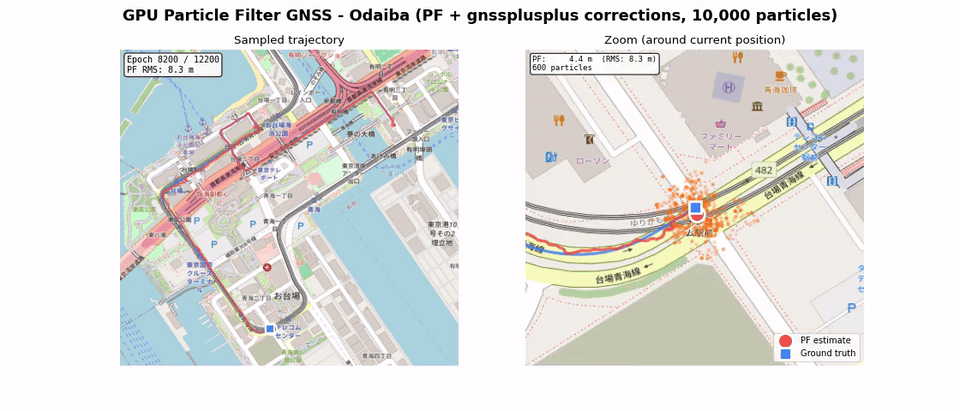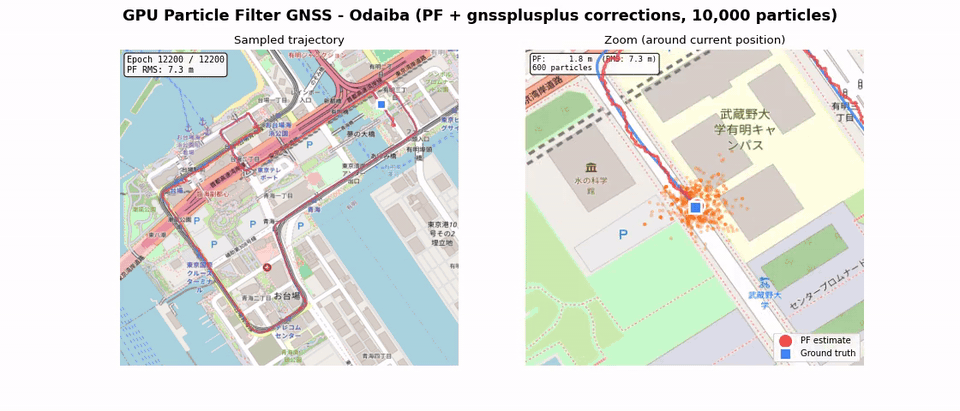
|
localization_zoo 55 stars C++ from-paper reimplementations of LiDAR localization and odometry papers, with benchmarks and tests. 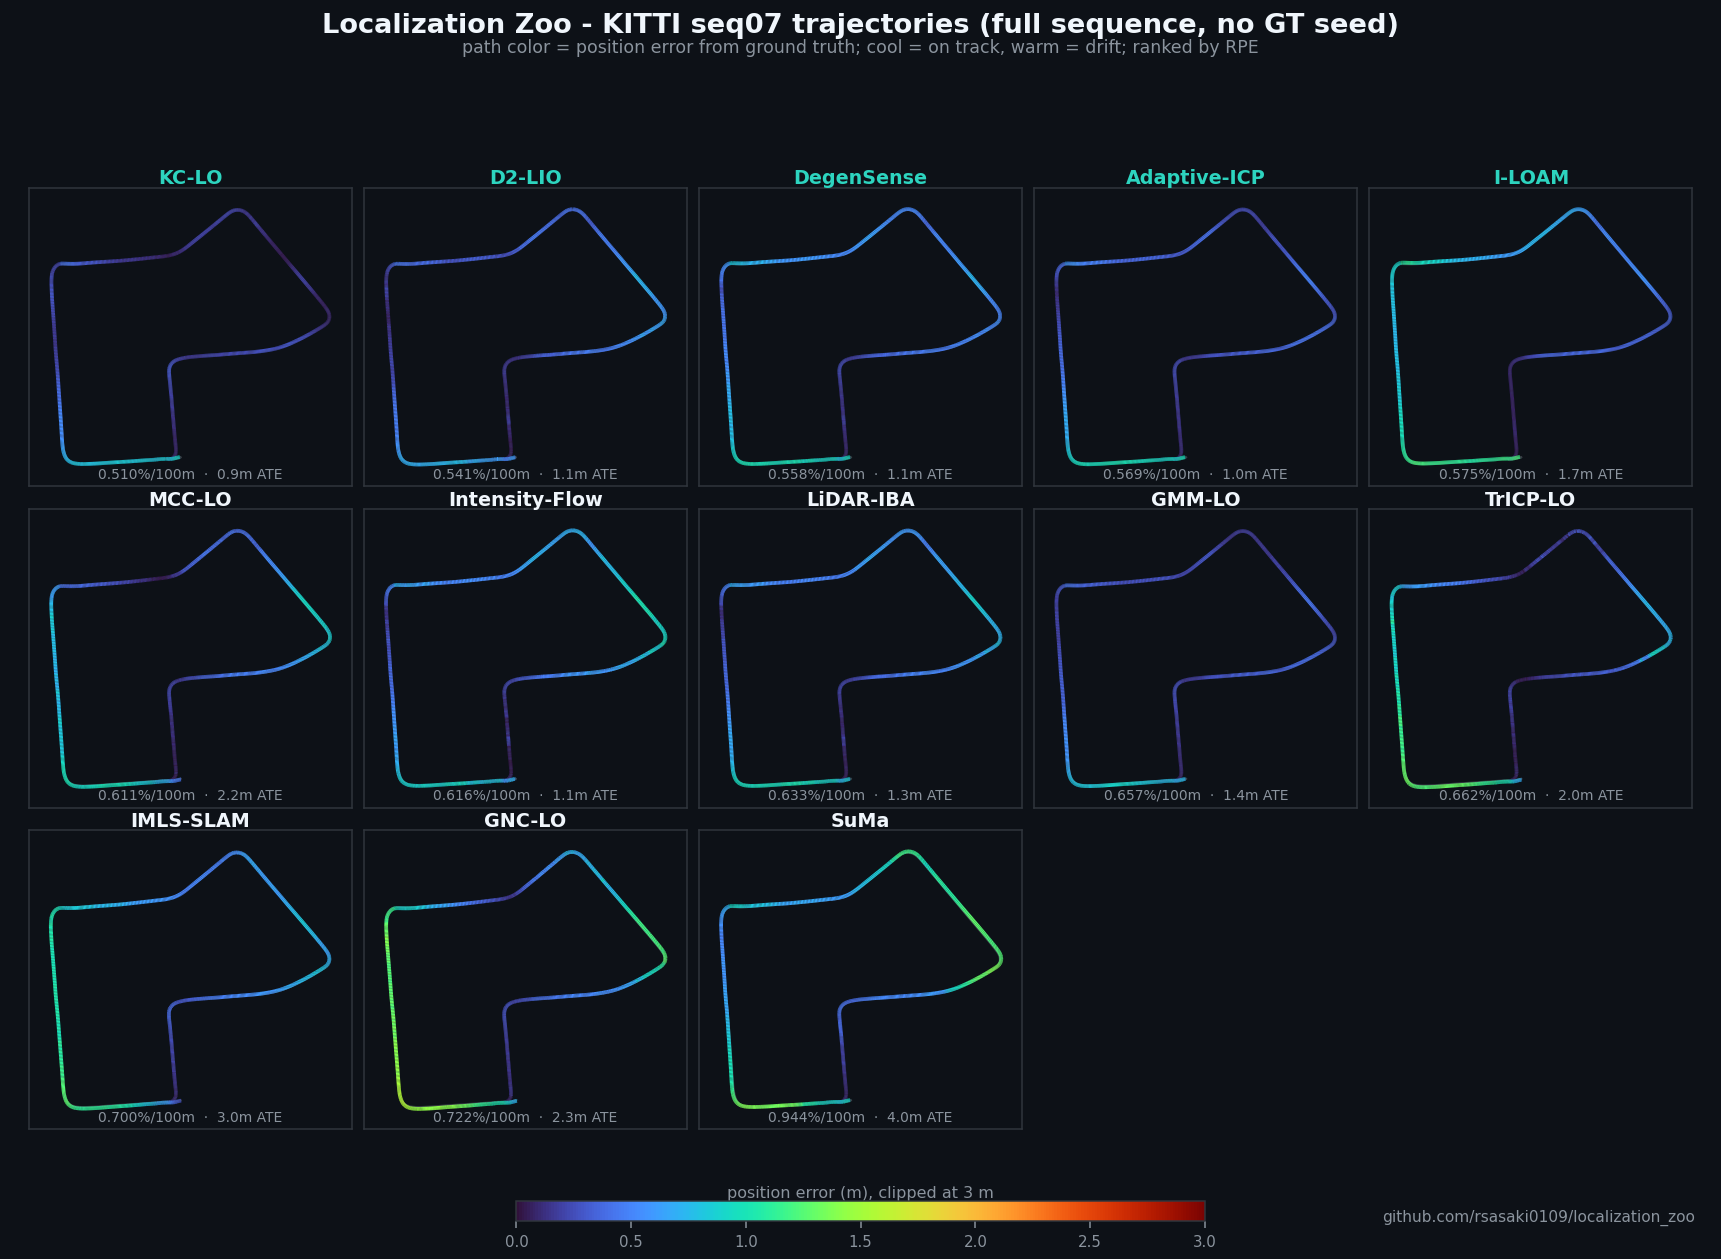
|
|
CudaRobotics 137 stars CUDA-accelerated robotics algorithms in C++ with 20+ SLAM, planning, and localization demos. 
|
dynamic-3d-object-removal 93 stars LiDAR dynamic object removal with public demos and a ROS 2 realtime node. 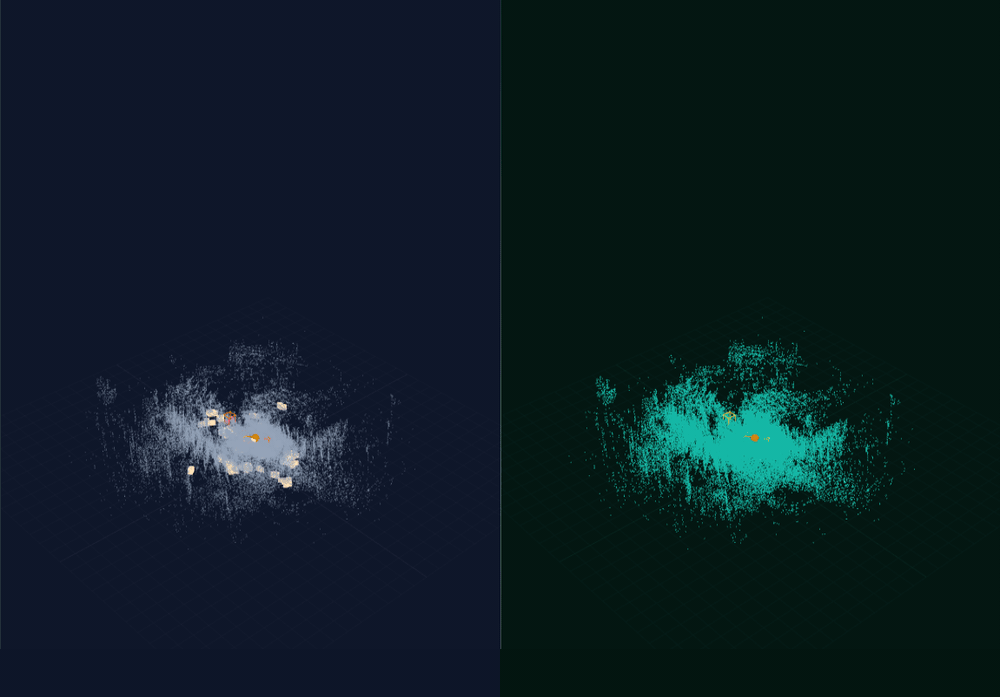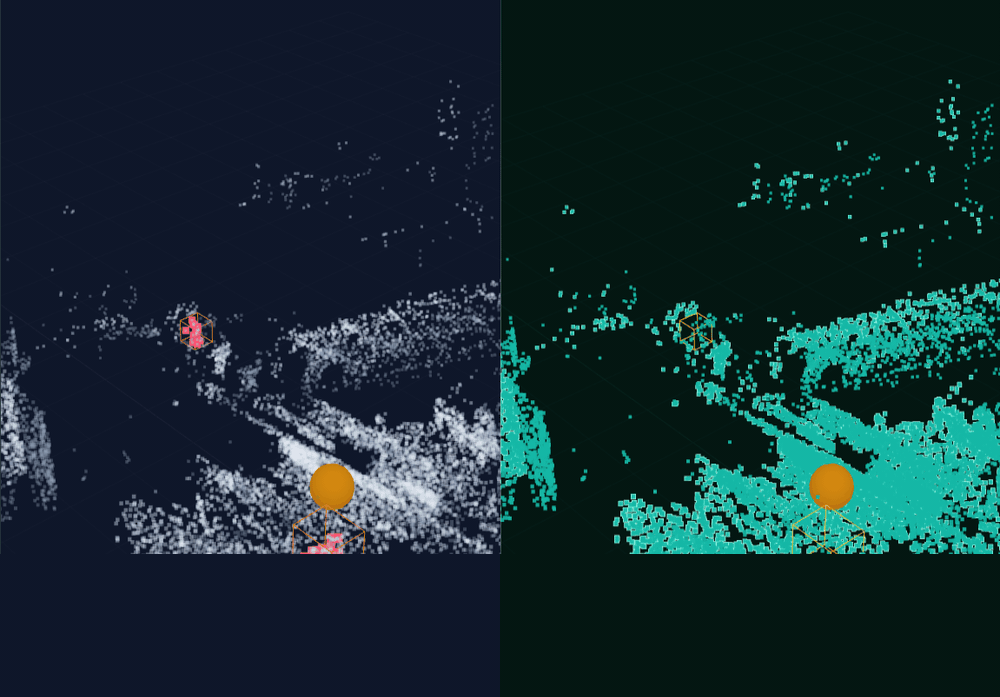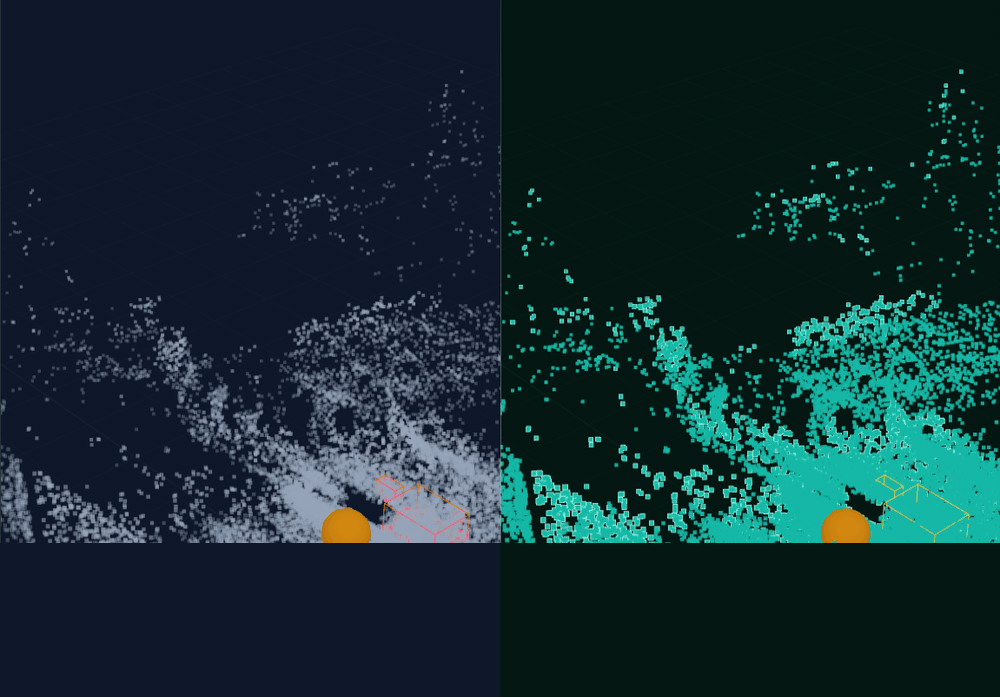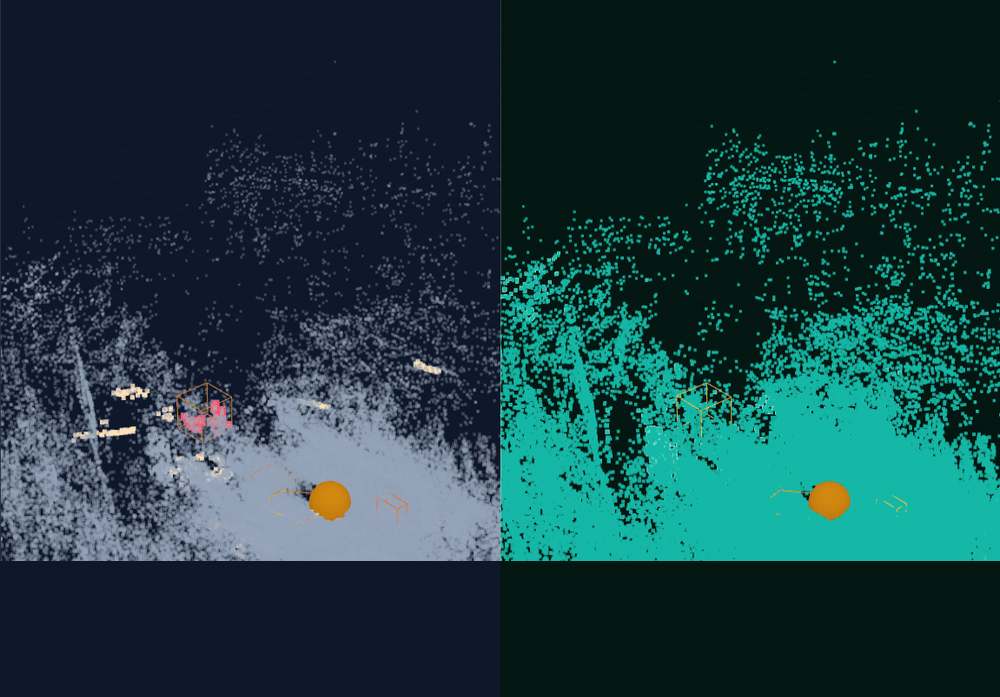
|